

President, rocket club
Mangystau region, Kazakhstan Club
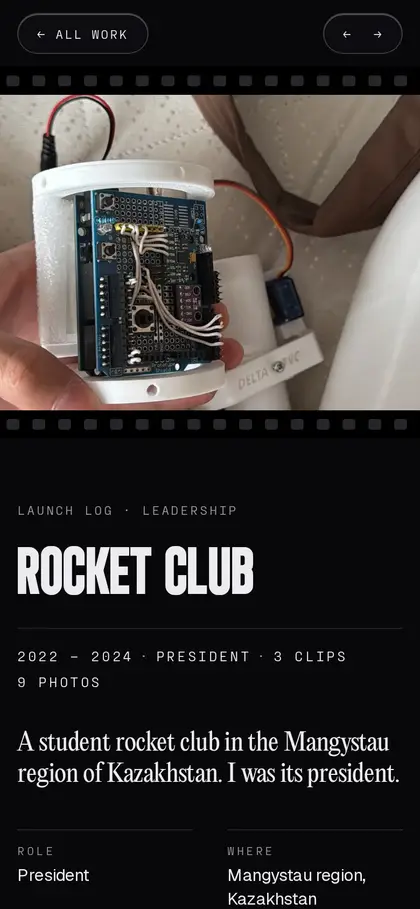
Printed airframes, avionics on the bench, and a design loop a beginner could join.
Open the caseRobotics · Software · ML. Computer Science, minoring in Physics, Oregon State University.
I work where robotics, software and machine learning meet. In Prof. Raffaele De Amicis's lab at Oregon State I am building a MuJoCo simulation of a robot arm and hand, with reinforcement learning in MuJoCo Playground, imitation learning with LeRobot and ACT, and VR teleoperation on a Quest through Unity and OpenXR. It is in progress, so there are no results here yet. Before it came a haptic glove, OLED glasses and printed rocket airframes.
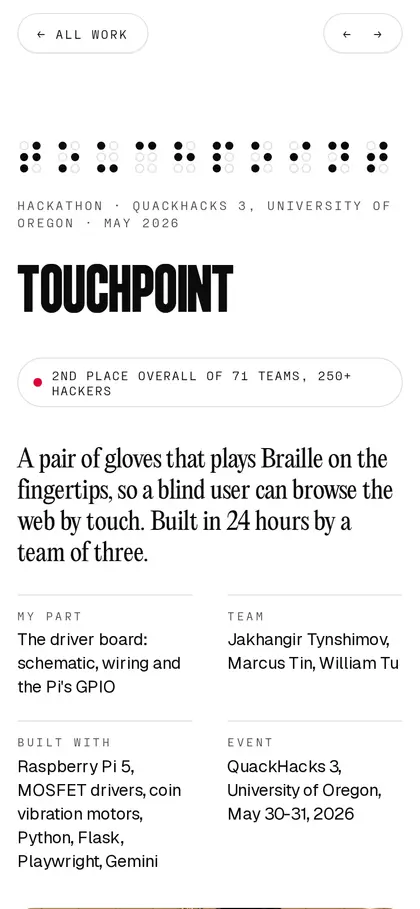
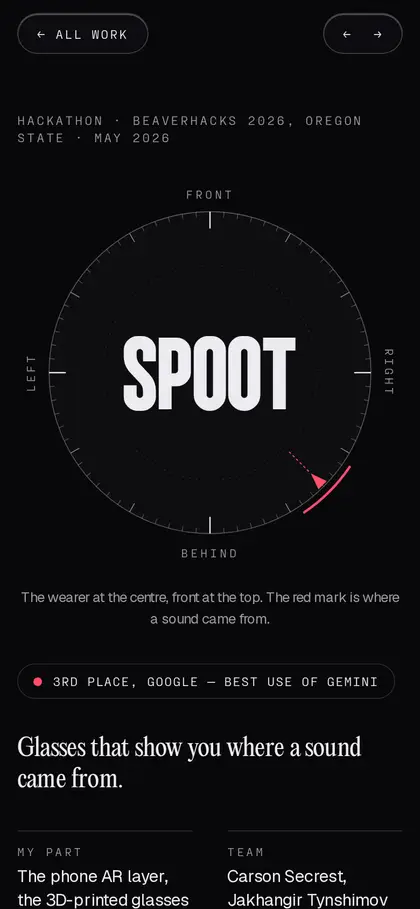
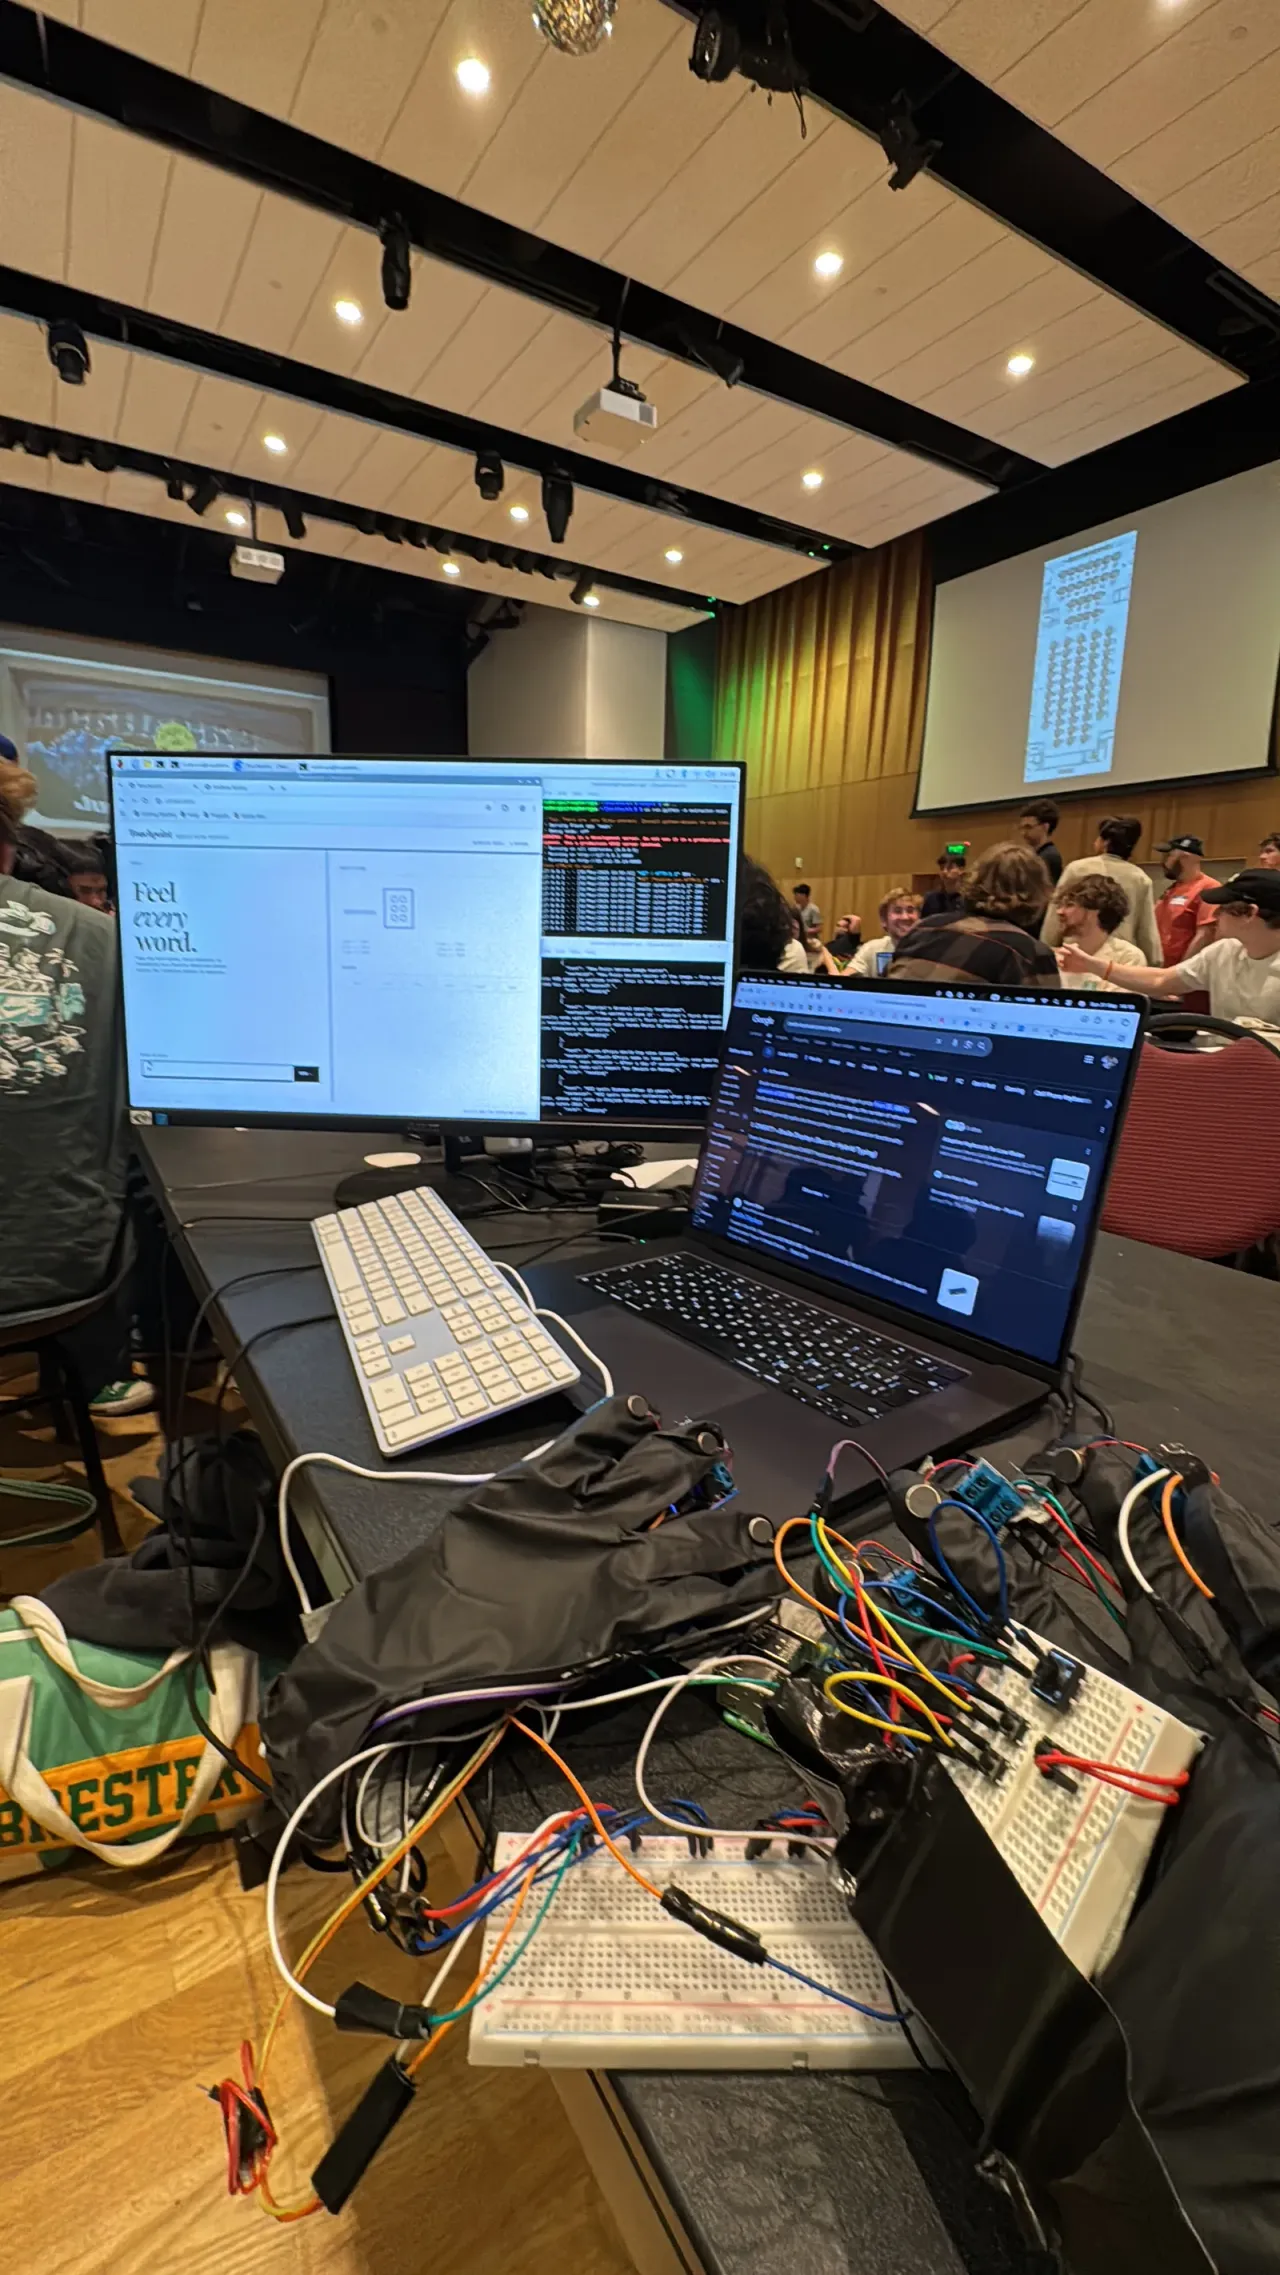
TouchPoint took 2nd place overall of 71 teams at QuackHacks 3. SPOOT placed 3rd in Google's Best Use of Gemini track at BeaverHacks 2026. Both were built from nothing inside a day, by teams of two and three.
This site has a performance harness that runs against the production build in three engines and reports frame timing, long tasks, forced reflows and listener growth. Every fix carries its before and after numbers, and the hypotheses that failed are written down. The robot-learning work follows the same rule: nothing about it goes on this page until it has been measured.
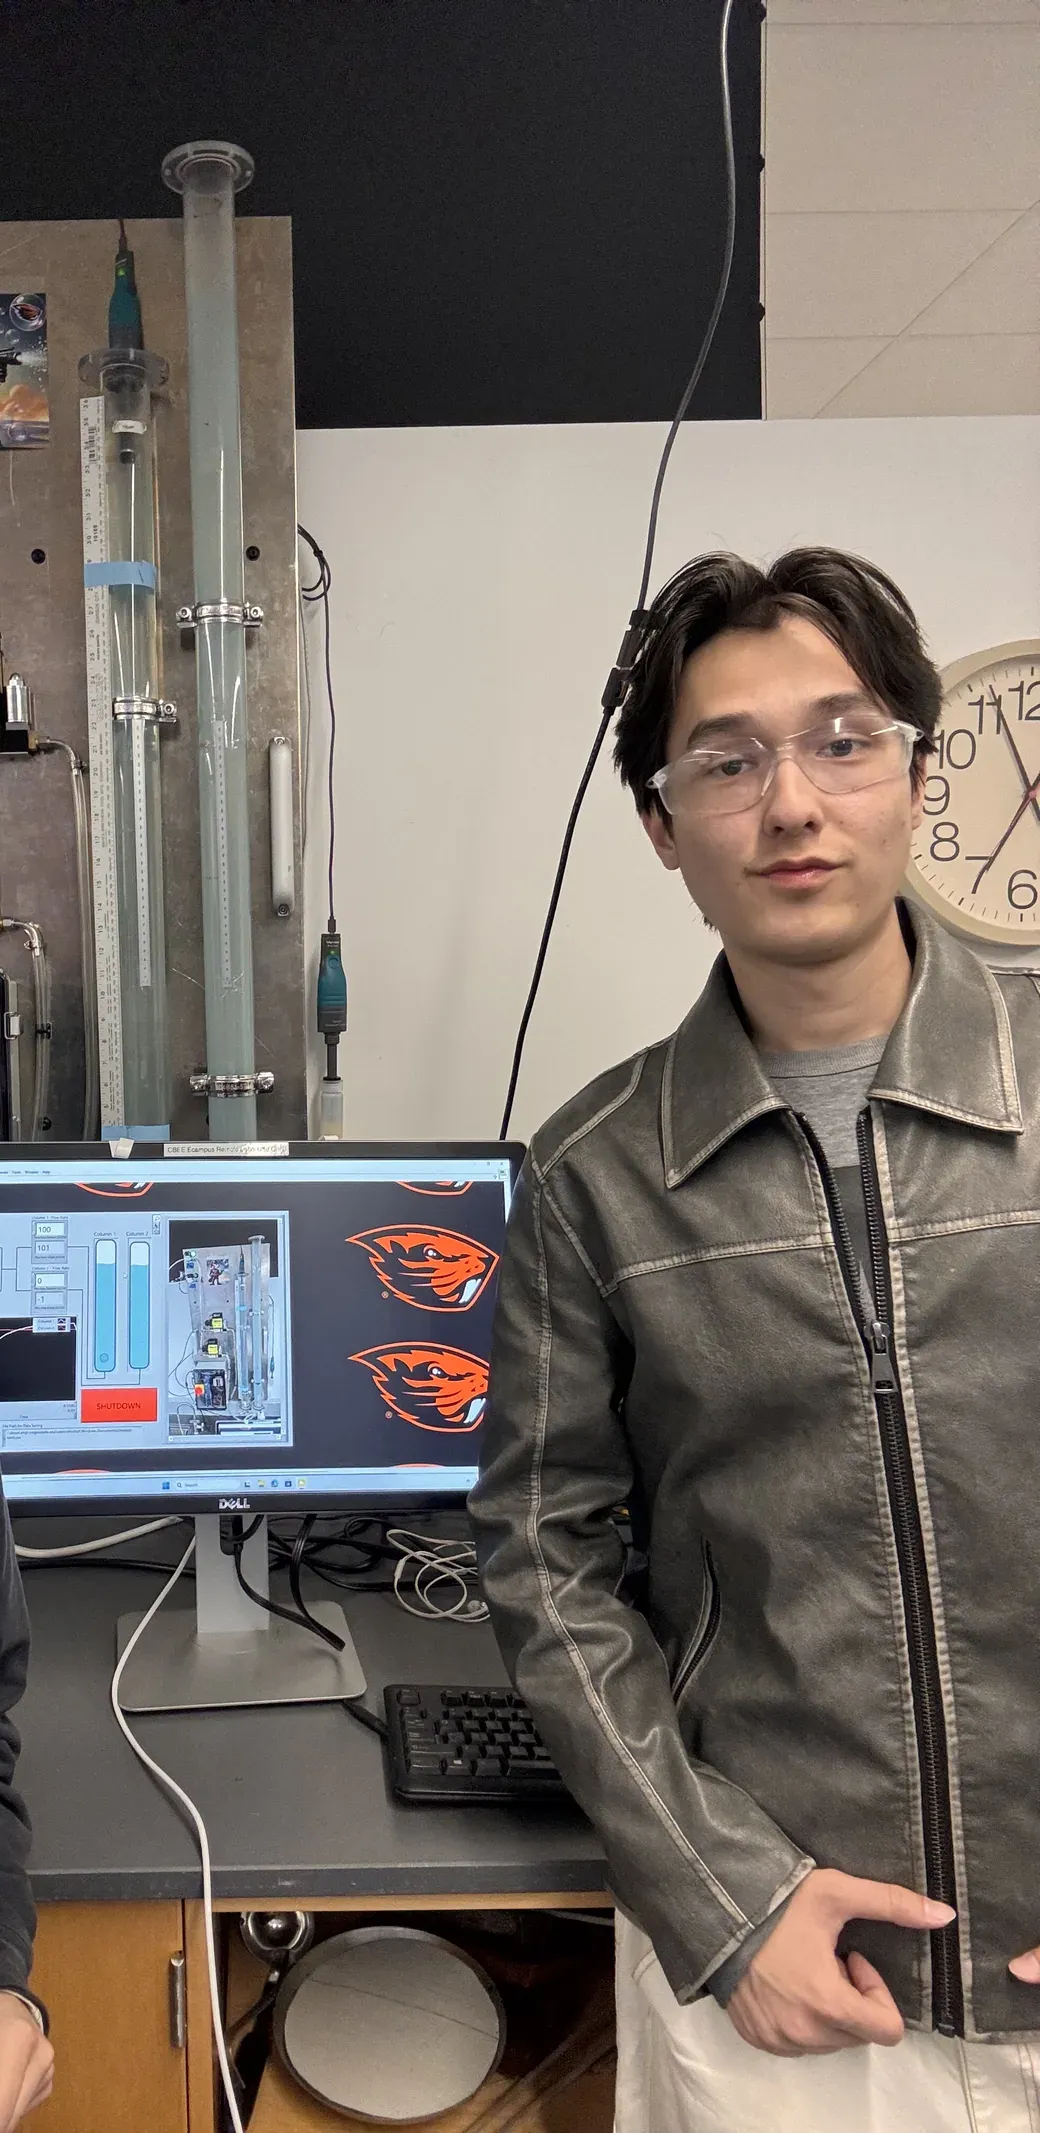
URSA Engage funded me to answer one question for Oregon State's remote chemistry labs: which camera can hold a readable feed inside LabVIEW. Four cameras, RGB intensity histograms, one recommendation the lab now builds against.
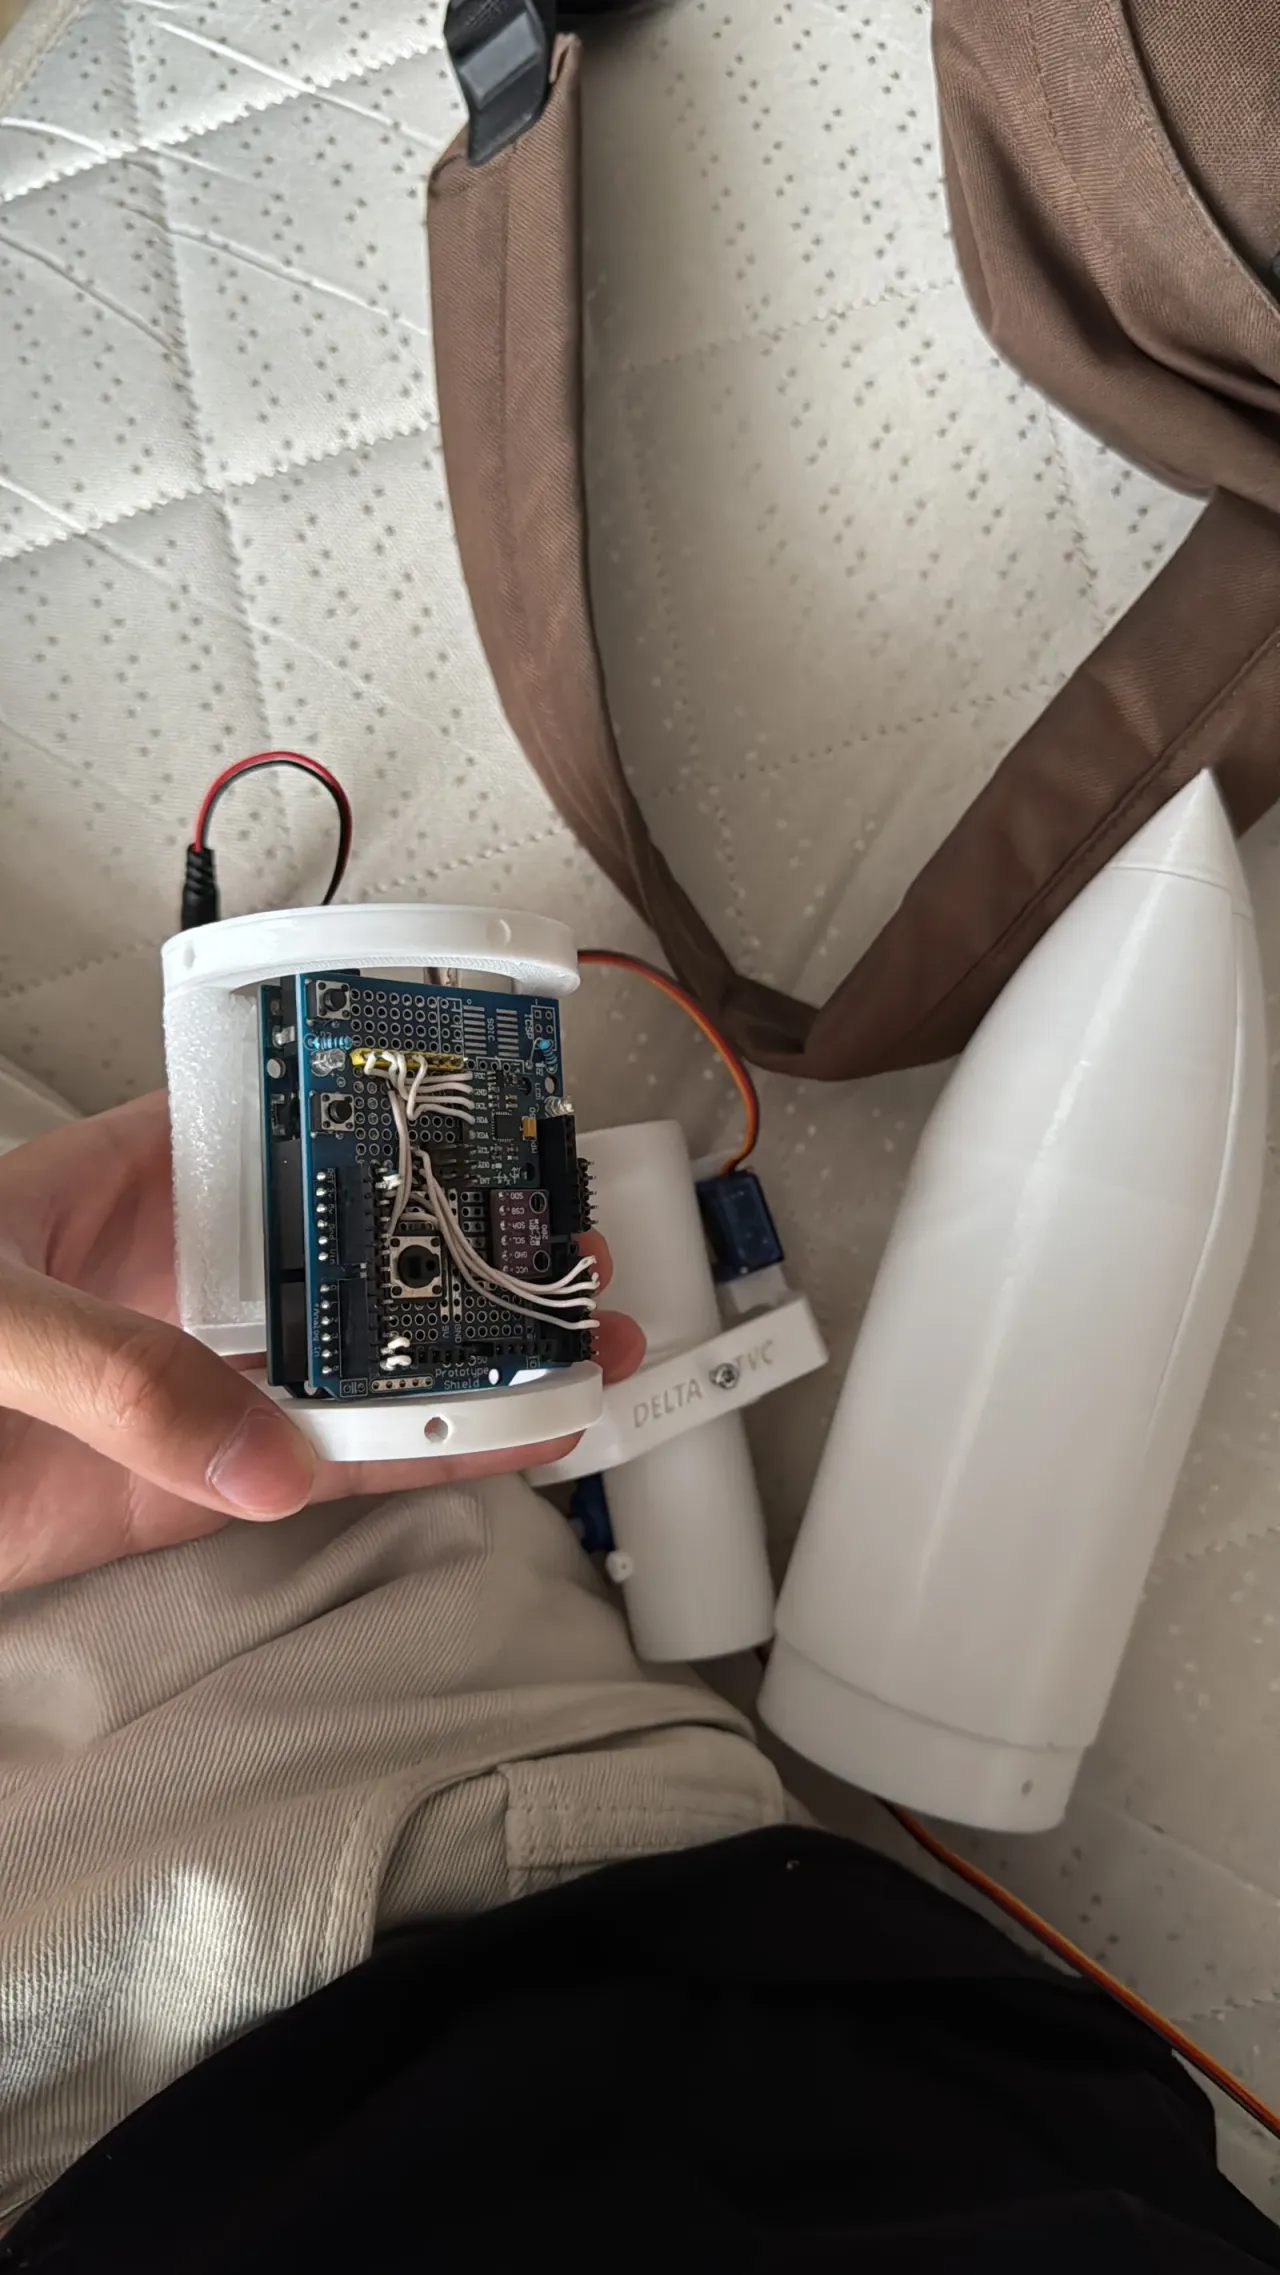
I ran a rocket club at a faculty of science and technology, where the job was less about rockets than about a loop a beginner could join: design a part, print it, find out why it failed, do it again.
Mangystau region, Kazakhstan Club
Printed airframes, avionics on the bench, and a design loop a beginner could join.
Open the case
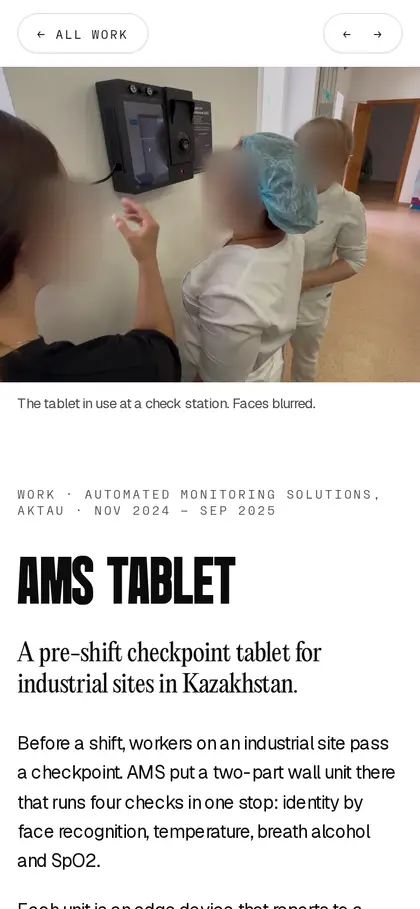
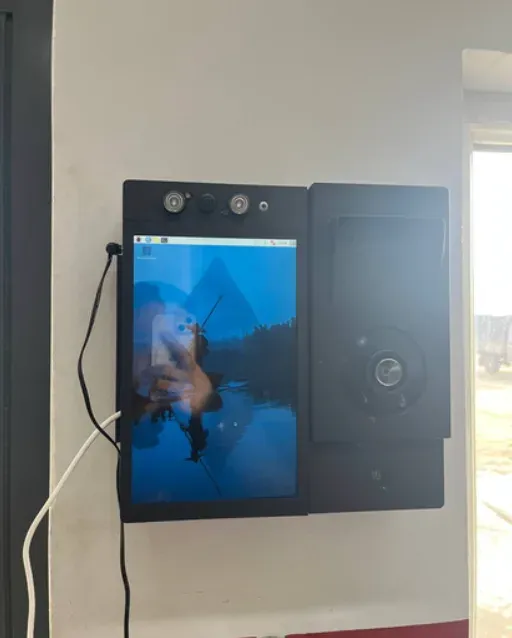
Automated Monitoring Solutions, Aktau Work
Pre-shift inspection and workforce verification at industrial checkpoints.
Open the case
Rowerlab, Poland (remote) Work
A Polish bicycle store's site: analytics, SEO and page speed, measured before and after.
URSA Engage, Oregon State Research Oregon State
Which camera can hold a readable feed inside LabVIEW, answered with histograms.
Open the case
Aktau, Kazakhstan Work
The clinic's booking channel: doctor search, patient accounts, three languages.
Open the case
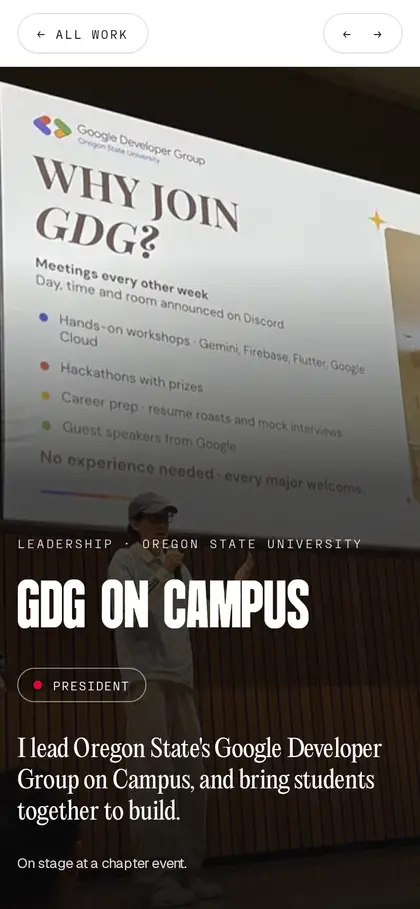
Oregon State Club Oregon State
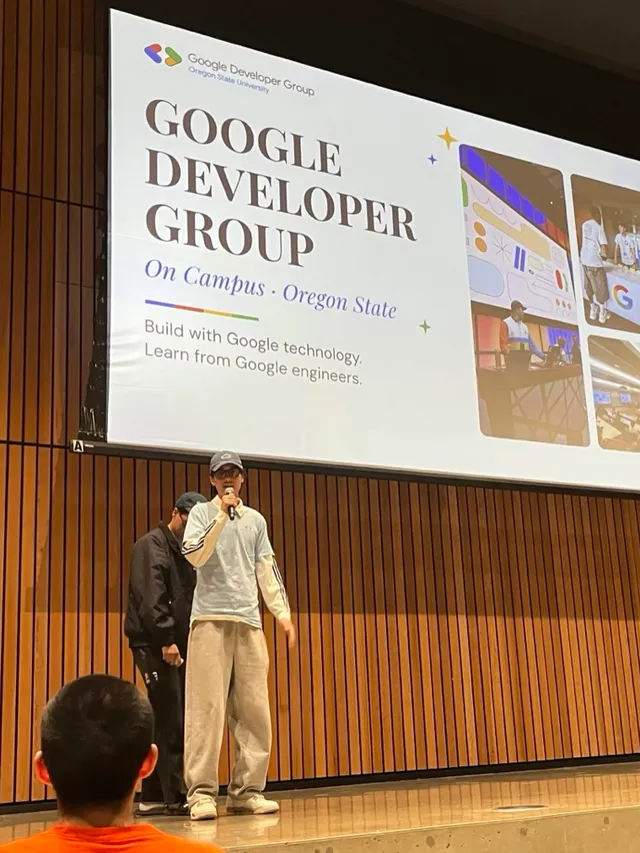
Leading Oregon State's GDG chapter: workshops and events, 200+ students registered.
Open the case
QuackHacks 3, University of Oregon Hackathon Oregon State
A haptic glove for deafblind web browsing. 2nd place overall of 71 teams, QuackHacks 3.
Open the case
BeaverHacks 2026, Oregon State Hackathon Oregon State
Glasses that show where a sound came from. 3rd in Google's Best Use of Gemini track.
Open the case
Prof. Raffaele De Amicis's lab, Oregon State Research Oregon State in progress
MuJoCo simulation of a robot arm and hand: RL in MuJoCo Playground, imitation learning with LeRobot and ACT, VR teleoperation on a Quest. In progress.
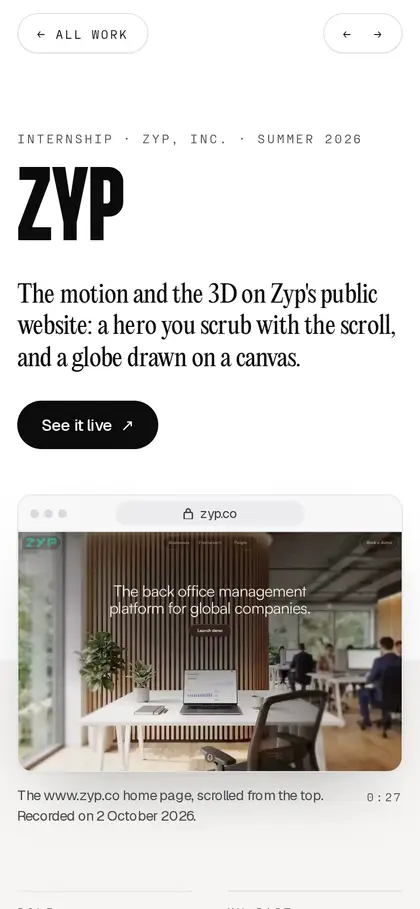
Zyp Work
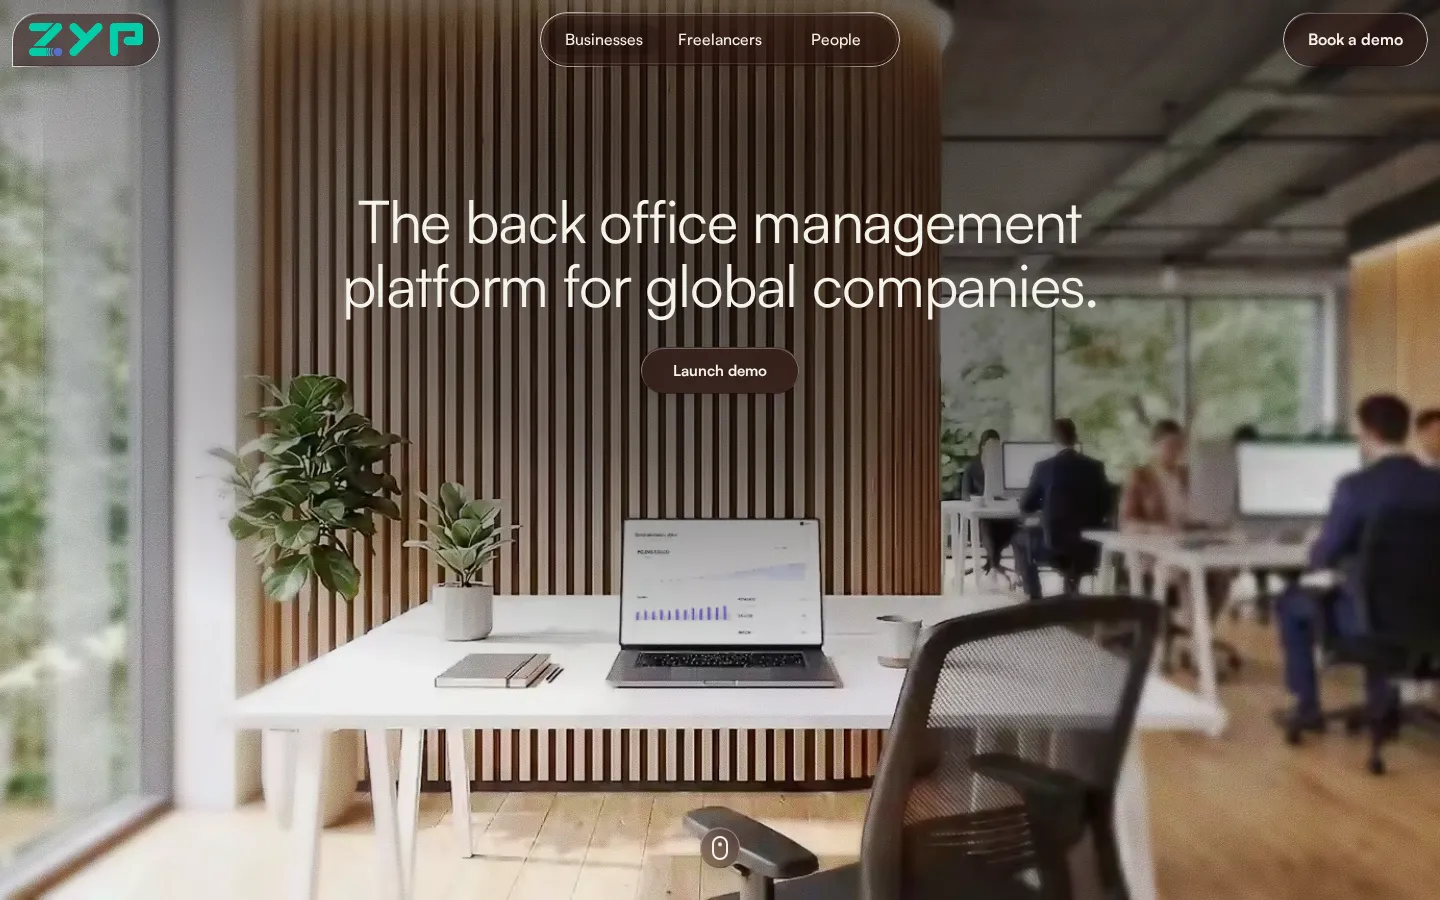
Motion and 3D on the company's site: a scroll-scrubbed hero, a canvas globe, end-to-end tests.
Open the caseContact
Corvallis, Oregon ·